Robotics & Autonomous Systems
Autonomous Ground Vehicles, Deterministic Embedded Architecture & Multi-Modal Perception
Engineering rugged unmanned ground platforms, hardware time-synchronized sensor suites, low-latency control loops, and multi-modal localization pipelines capable of operating in GPS-denied unstructured outdoor environments.
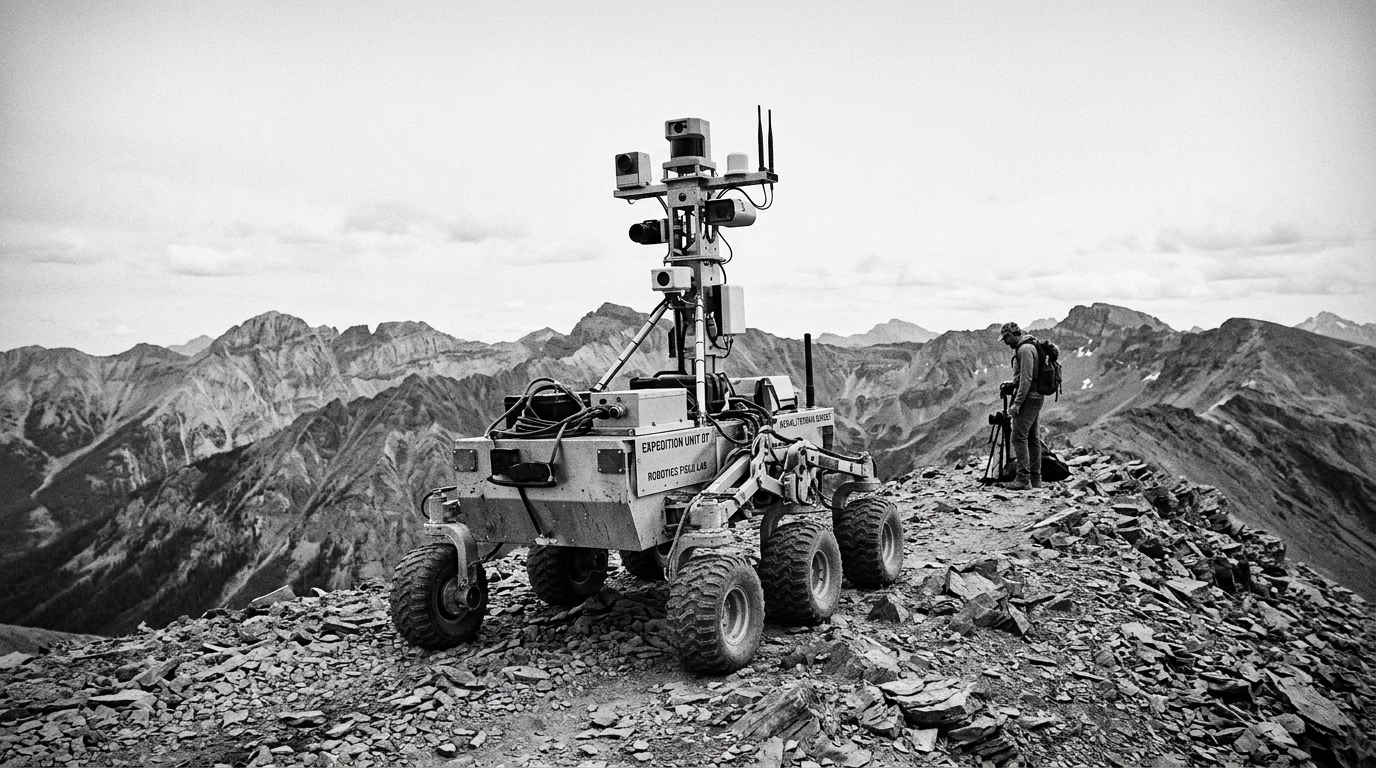
Avni Autonomous Ground Vehicle
Deep-Terrain Competition Rover Platform — UGVC 2026 (Egypt)
Full-stack autonomous rover engineered to conquer GPS-denied, unstructured outdoor terrain. Features custom inverted-V suspension mechanics, 4WD direct BLDC hub-motor drive, and deterministic 11.8ms real-time control loops under ROS 2 Jazzy.
- Developed multi-drop CAN-FD bus architecture with galvanic isolation separating high-current motor drivers from central compute.
- Implemented hardware Pulse-Per-Second (PPS) triggering across stereoscopic cameras and high-precision IMU, eliminating temporal frame jitter.
- Integrated 3D LiDAR point cloud processing, stereoscopic depth estimation, and wheel odometry into a unified 50Hz costmap.
- Engineered fail-safe hardware watchdog e-stops with autonomous braking deceleration envelopes.
Adaptive Sensor Fusion Research
IEEE 44th ICCE (Las Vegas) covariance convergence plots and gravel obstacle test trajectories will be supplied in the next phase.
K_k = P_{k|k-1} H_k^T (H_k P_{k|k-1} H_k^T + \Lambda_k R_k)^{-1}AGNI: Adaptive Sensor Fusion Research
Hybrid Confidence-Adaptive Fusion (HCAF) — IEEE 44th ICCE
Formulated the novel Hybrid Confidence-Adaptive Fusion (HCAF) architecture, dynamically scaling Kalman gains during sensor degradation (dust occlusions, GPS dropouts, encoder slip). Published and presented at the IEEE 44th International Conference on Consumer Electronics.
- Achieved ~32% reduction in localization error compared to standard extended Kalman filtering across rugged outdoor terrain.
- Demonstrated 95.5% autonomous navigation success rate on mixed gravel and slope courses without GPS availability.
- Coupled terrain-aware Dynamic Window Approach (DWA) local planner with real-time IMU vibration feedback loop.