Work
An exploration of machines, intelligence and digital systems.
A focused presentation of five engineering systems: production-scale web platforms serving 50,000+ national students, cross-platform mobile client suites with sub-50ms ephemeris computation, deep-terrain autonomous competition rovers, peer-reviewed sensor fusion algorithms, and sandboxed multi-agent AI operating systems.
Primary Flagships
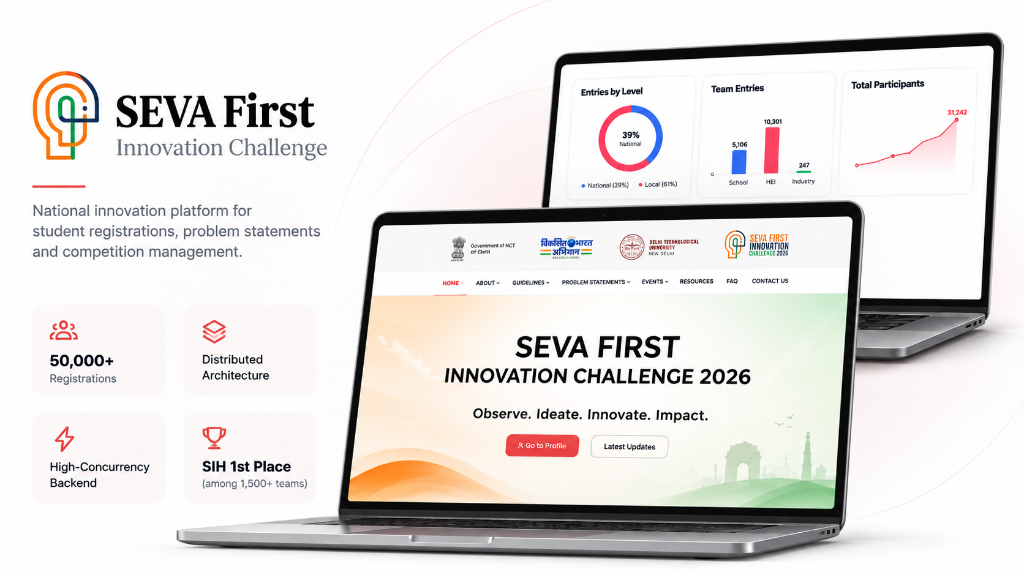
SEVA First Platform
High-Concurrency Distributed Architecture Serving 50,000+ Student Registrations
Recognized by the Ministry of Education & AICTE and winning 1st place at Smart India Hackathon among 1,500+ institutions. Engineered with Go microservices, Redis distributed caching, and PostgreSQL schemas handling deadline traffic spikes with 180ms response times.
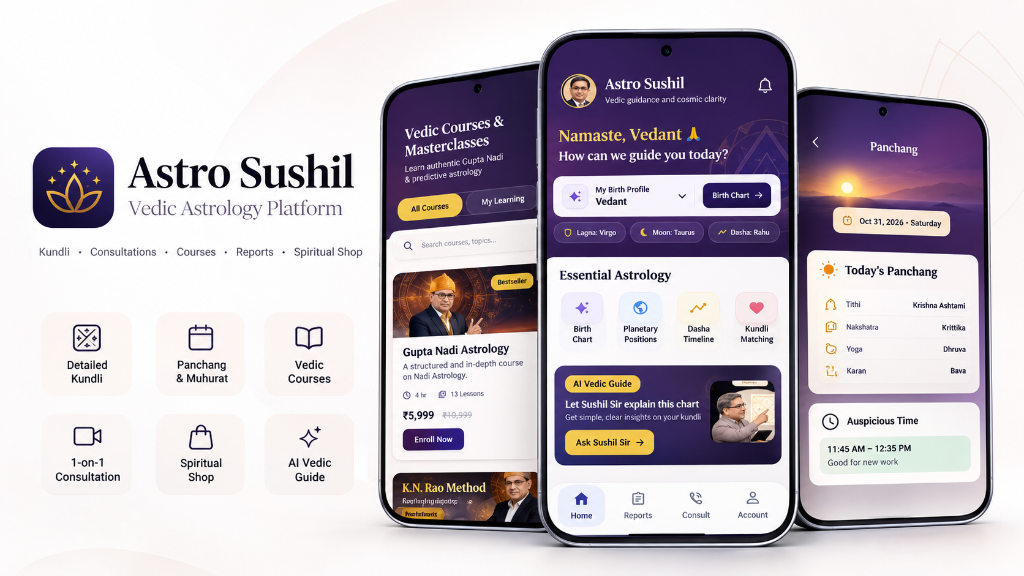
Astro Sushil Mobile & Web
Production Vedic Astrology Platform with Sub-50ms Ephemeris Engine
Integrated monorepo uniting a native Flutter mobile client with a Next.js admin portal and Prisma/PostgreSQL backend. Powered by offline Swiss Ephemeris C-bindings computing planetary longitudes in under 50ms and custom 60 FPS Kundali rendering.
Autonomous Systems & AI
Field Robotics & Operating Systems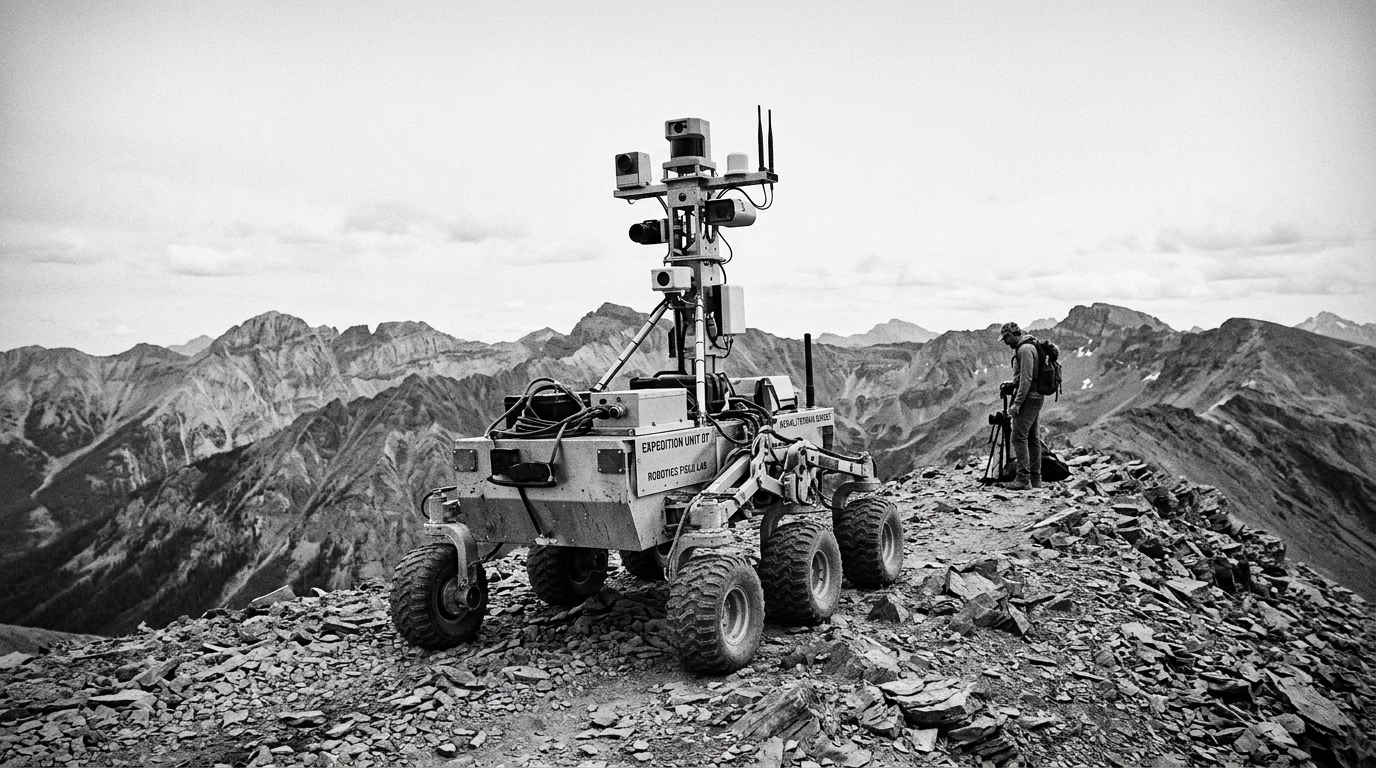
Avni Rover
Deep-terrain competition rover platform with inverted-V suspension, isolated CAN-FD bus, and 11.8ms deterministic ROS 2 control loops.
AGNI Sensor Fusion
IEEE 44th ICCE (Las Vegas) research visuals pending.
K_k = P_{k|k-1} H_k^T (H_k P_{k|k-1} H_k^T + \Lambda_k R_k)^{-1}AGNI Sensor Fusion
Hybrid Confidence-Adaptive Fusion (HCAF) dynamically scaling Kalman gains during sensor degradation, reducing error by ~32% over standard EKF.
FlawCode Multi-Agent OS
Hermes orchestrator state machine logs pending.
FlawCode (ForgeOS)
Multi-agent AI software engineering OS with Hermes state machine, isolated Docker sandboxing, AST verification, and real-time Slack streaming.